"Many robotic designs take nature as their muse: sticking to walls like geckos, swimming through water like tuna, sprinting across terrain like cheetahs. Such designs borrow properties from nature, using engineered materials and hardware to mimic animals’ behaviour.
Scientists at MIT and the University of Pennsylvania have genetically engineered muscle cells to flex in response to light, and are using the light-sensitive tissue to build highly articulated robots."
Holy cows! A friend just shared this video on my wall on Facebook. I realize it's just concept and a lot of things happen in "just concept" these days, but this is sooo bleeding impressive!
Morph is a new concept design by Nokia, that supposedly will revolutionize mobile devices using a whole load of nano-tech. Read more about it here.
"Dennis Hong, a professor of mechanical engineering and director of Virginia Tech's Robotics & Mechanisms Laboratory, or RoMeLa, has created robots with the most unusual shapes and sizes -- from strange multi-legged robots to amoeba-like robots with no legs at all. Now he's unveiling a new robot with a more conventional shape: a full-sized humanoid robot called CHARLI, or Cognitive Humanoid Autonomous Robot with Learning Intelligence. The robot is 5-foot tall (1.52 meter), untethered and autonomous, capable of walking and gesturing. But its biggest innovation is that it does not use rotational joints."
Here's another serious competitor for ASIMO. I just came across this article on IEEE Spectrum and was pretty amazed by how natural some of this robot's moves are. And it actually looks pretty neat too! The wrist + finger movements / control impressed me the most.
This is something that I'm very much looking forwards to getting my hands on. It could very well be a life saver for me.
"On Monday, National Instruments announced one such platform. It's called LabView Robotics. In addition to LabView, the popular data-acquisition application, the package includes a bunch of tools specific to robotics. It can import codes in various formats (C, C++, Matlab, VHDL), offers a library of drivers for a wide variety of sensors and actuators, and has modules for implementation of real-time and embedded hardware. NI says engineers could use the package to both design and run their robotic systems."
Well this is just amazing! The possibilities of what can be done with this type of robot are infinite…
Apparently the blob design is about a year old… they have improved designs now that are a bit different, going towards the ability to include sensors… some are palms sized. This blew my mind….
I was just checking the latest ASIMO news when I came across U3-X, Honda’s new personal mobility device. Neat little device that you can comfortably sit on and move around, with adjustable speed and easy navigation through body gestures. Looks pretty kool to me!
I’ll be collecting more information here, as I find it…
I just came across a couple of very interesting videos on this article on BotJunkies. Both videos display pretty amazing navigation capabilities in robots, and the ability to recognize and avoid the obstacles, even moving ones. Most of the processing equipment for the HRP-2 robot are off board though, which is why I find ASIMO still a lot cooler. ;)
Well well, it appears Honda’s ASIMO has a serious competitor! While ASIMO’s fastest running speed has been 6km/h so far, this new Toyota humanoid is running at 7km/h. Also as seen in this video, this robot can do a nice job re-balancing itself when pushed slightly. This new Toyota robot’s stunningly natural running really amazes me. however, while standing, the legs look all things but natural. ;) Which is why I still like ASIMO better. =)
This article on IEEE spectrum is pretty awesome… check it out!
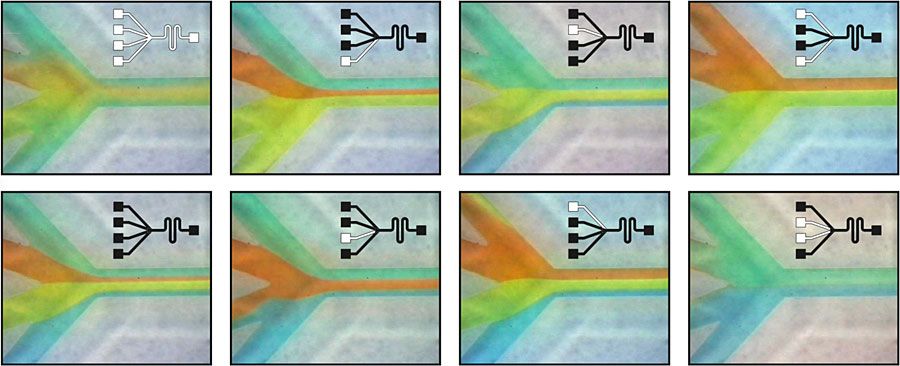
“Researchers at the University of Michigan have found a way to control the movement of tiny droplets of fluid in a microelectromechanical (MEMS) device—with sound. The scientists use several musical tones to move droplets along different channels on a chip. By combining tones or applying them at appropriate times, they can move liquids along multiple channels and even mix, split, and sort the liquids.
The advance, published this week in Proceedings of the National Academy of Sciences, holds promise for making microfluidic devices compact and simple. Microfluidic devices are glass or plastic chips with etched channels through which you can maneuver nano- or even picoliters of liquids. Thousands of chemical or biological reactions can be performed on the chips simultaneously, promising to speed up medical diagnostics, chemical synthesis, and drug discovery.”
“We have put together a video of our Milestone 2 run, which we completed this past Monday, June 1, 2009. This particular run had our PR2 alpha robot navigate through eight doors, and plug its power cord into nine outlets. In this video, you can see the various challenges our robot faced, such as a crowded office environment and the abrupt appearance of a human obstacle. We nearly sabotaged the run early on. Folks around the office were eager to track the progress of the robot, so many people ran their own monitoring programs on the PR2. This caused an increase in CPU load, starving the navigation software. Nonetheless, the robot was able to continue with the run, albeit more slowly and cautiously.”
“We are currently developing algorithms that will narrow the learning gap between humans and machines, and enable flight systems to ‘learn’ the way humans do: through practice.
Rather than being programmed with detailed instructions, these flight systems will learn from experience. Like baby birds leaving the nest, they will be clumsy at first. Over time, however, they will become capable of sophisticated, coordinated maneuvers……”
A friend of mine had posted this video to my twine a while go, and I finally got a chance to watch it. I find it very interesting so I decided to share!
I also checked out the fold.it game mentioned in this video. Quite entertaining! =)
This video isn't thaaaat new, but I came across it today while looking for videos relevant to this article that has to do with Phoenix lander's mission to land on Mars. It's a simulation that was created last year, but I hadn't seen it before and I fell in love with it instantly. Good music for the purpose too by the way. And if you don't understand Spanish don't worry, just wait for the actual video to start.
Earlier I had posted a few lines in regards to ASIMO's conduction of the Detroit Symphony Orchestra performing "Impossible Dream". Today I received an email from a good friend of mine notifying me that the video for the performance has just been released and it's currently available on blip.tv. So, here it is, and it's profoundly cute. =D Enjoy!
Well apparently his majesty the royal cuteness Honda's ASIMO robot is planning on mesmerizing the audience by conducting the Detroit Symphony Orchestra performing "Impossible Dream". This is going to be the opening for cellist Yo-Yo Ma's performance. Read the whole story here. Cool ha? =) I have been tracking the improvements and basically the process of "growing up" of this little creature from the start, as he's pretty much the "Dream Come True" of Robotics enthusiasts such as myself. And I even had him as the topic for the papers for a couple of my engineering design related courses. Now I wonder if the videos for this performance are going to show up on YouTube, cause I have to say, I so badly want to see this! =D
Also, look what I just dugg up! The article just amazes me, check it out! :)
"It's a bird. It's a plane. Or it might turn out to be a little like both. Researchers are aiming to find ways to enable aircraft to change shape during flight to improve performance or efficiency. The University of Dayton project is funded by a $580,000 defense contract to further the development of "morphing" aircraft..."
The IEEE website has a new design. I don't know how long it's been there, less than a week probably, but I noticed it last night. The significance of this? Well....just that I really "disliked" the old one. It was quite disorganized, the design of each part of the website sang a different song and certain parts of it were quite ugly! Altogether I thought that for an organization of such size they could probably do better, and since this thought kept coming to my mind every time I visited that site, it was nice to see they actually did something about it. The new design is nice and well organized, so....good job to whoever took care of it! Now was that "significance" enough? Or is it that there's about 15 minutes left to my next class and I'm just incredibly bored?? And yes, I'm posting this from ENG406, on the 4th floor of Ryerson Engineering Building. :P
This weblog is a
collection of my random thoughts. It's as simple as that. What I write here
is for my friends, or anyone else who might find it worth reading. This is
not a tech blog, a science blog, a lyrics blog or...although you might find
either one of those topics in here "randomly". I appreciate comments very much, so
if you have any thoughts about something that you read here please drop me a
line and let me know. So...after all this, welcome to my weblog, thanks for
visiting and enjoy your stay! =)



 Friday, May 03, 2013

 geckos, swimming through water like tuna, sprinting across terrain like cheetahs. Such designs borrow properties from nature, using engineered materials and hardware to mimic animals’ behaviour.